M3
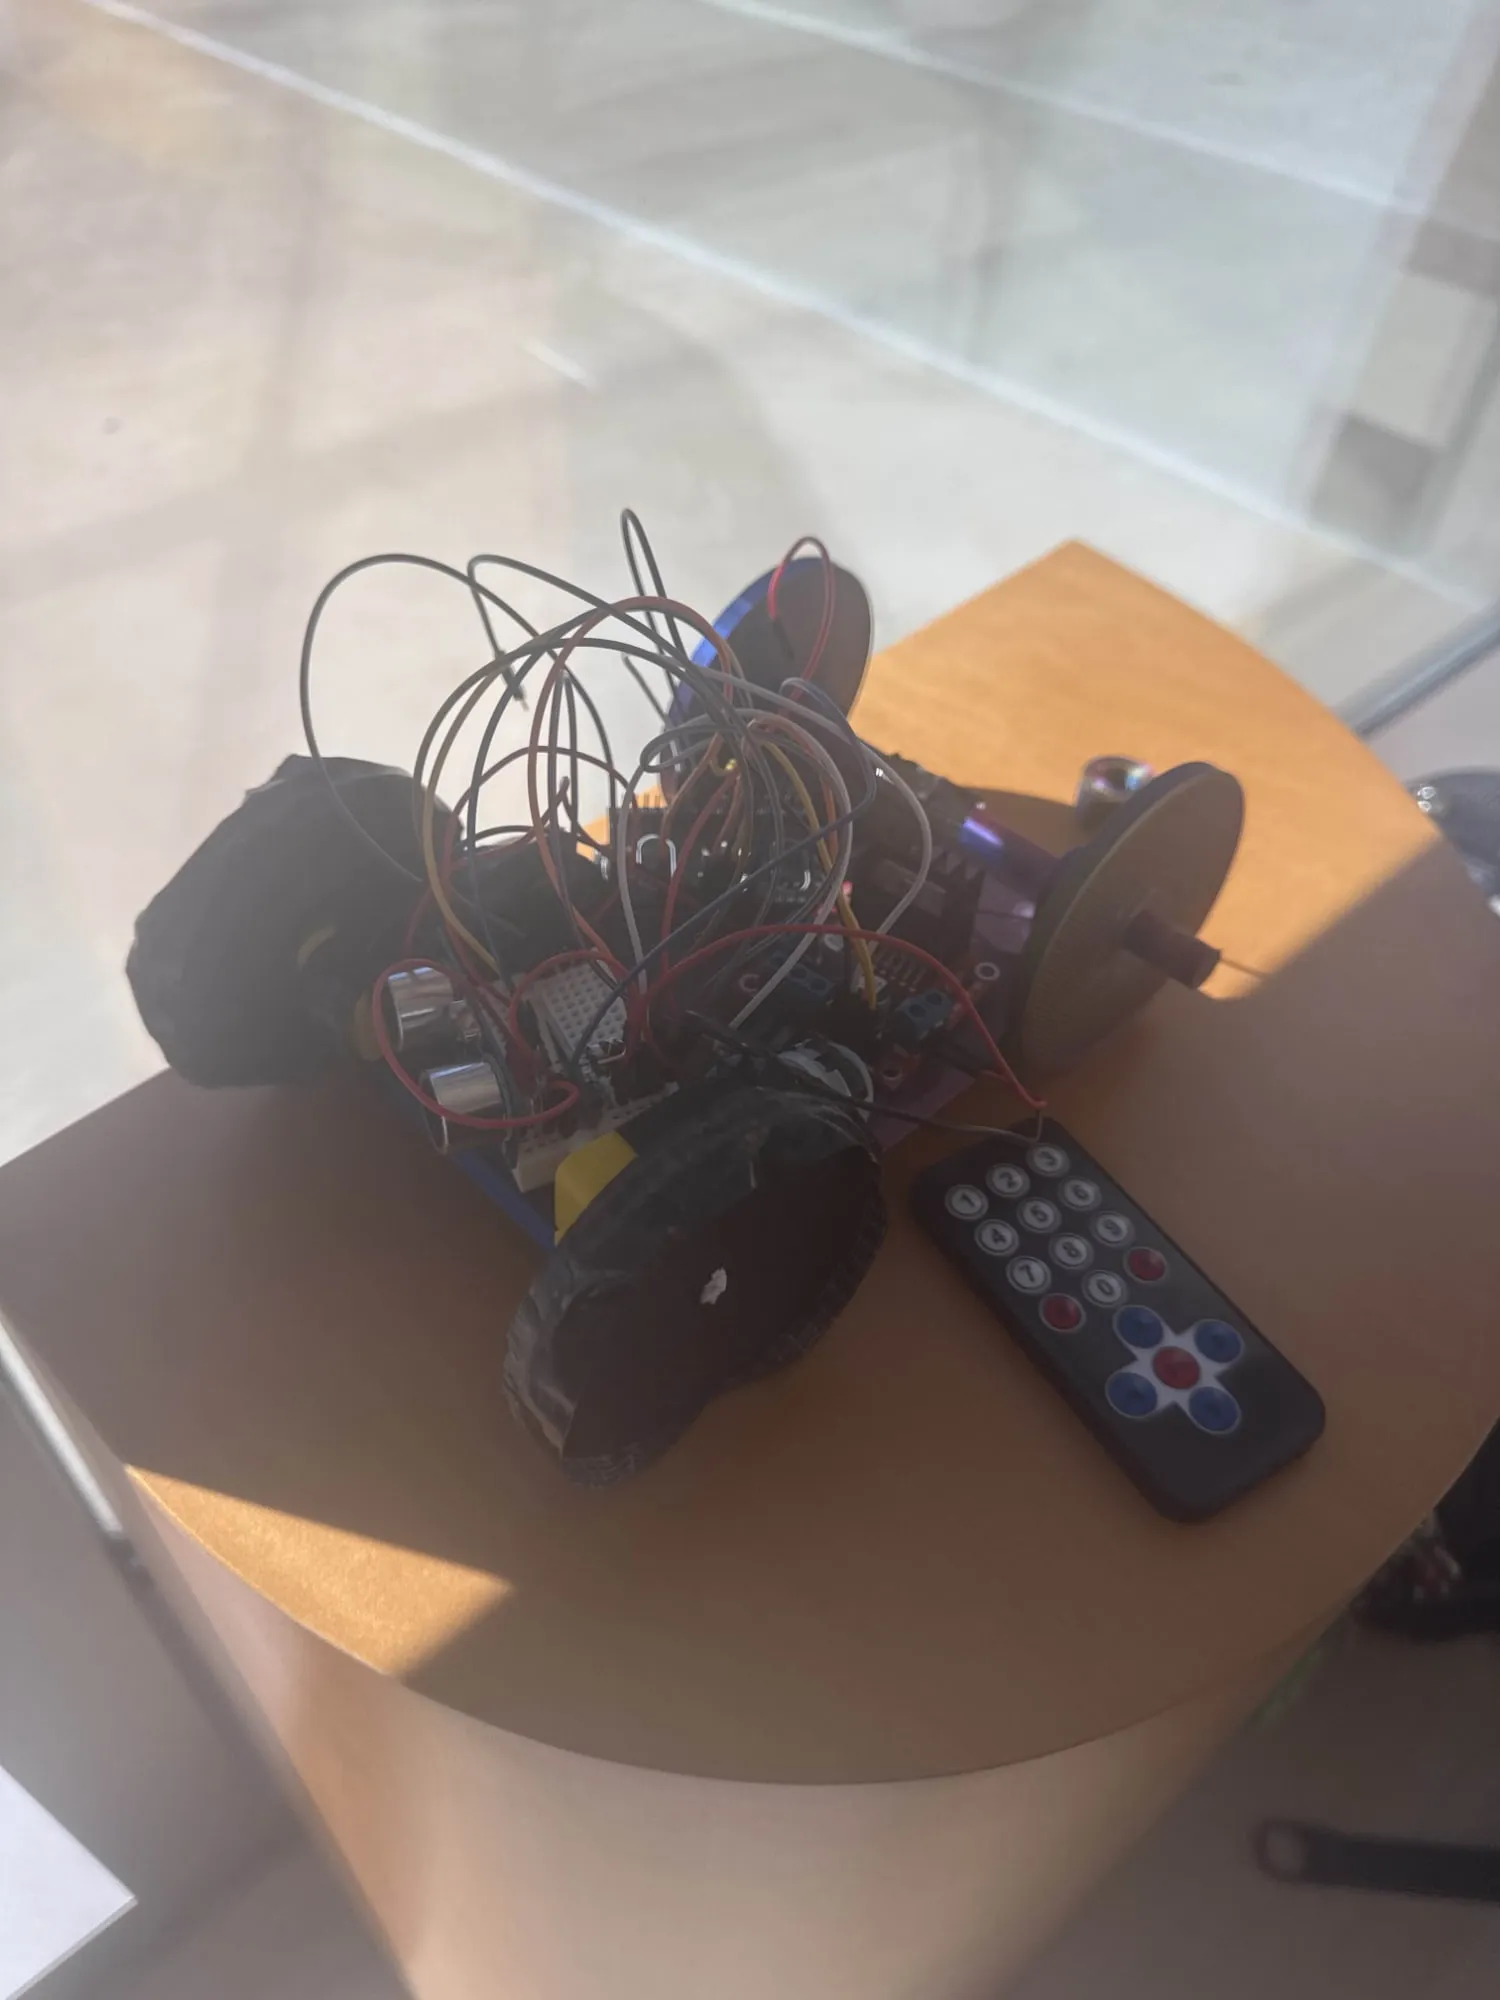
Autonomous competition robot
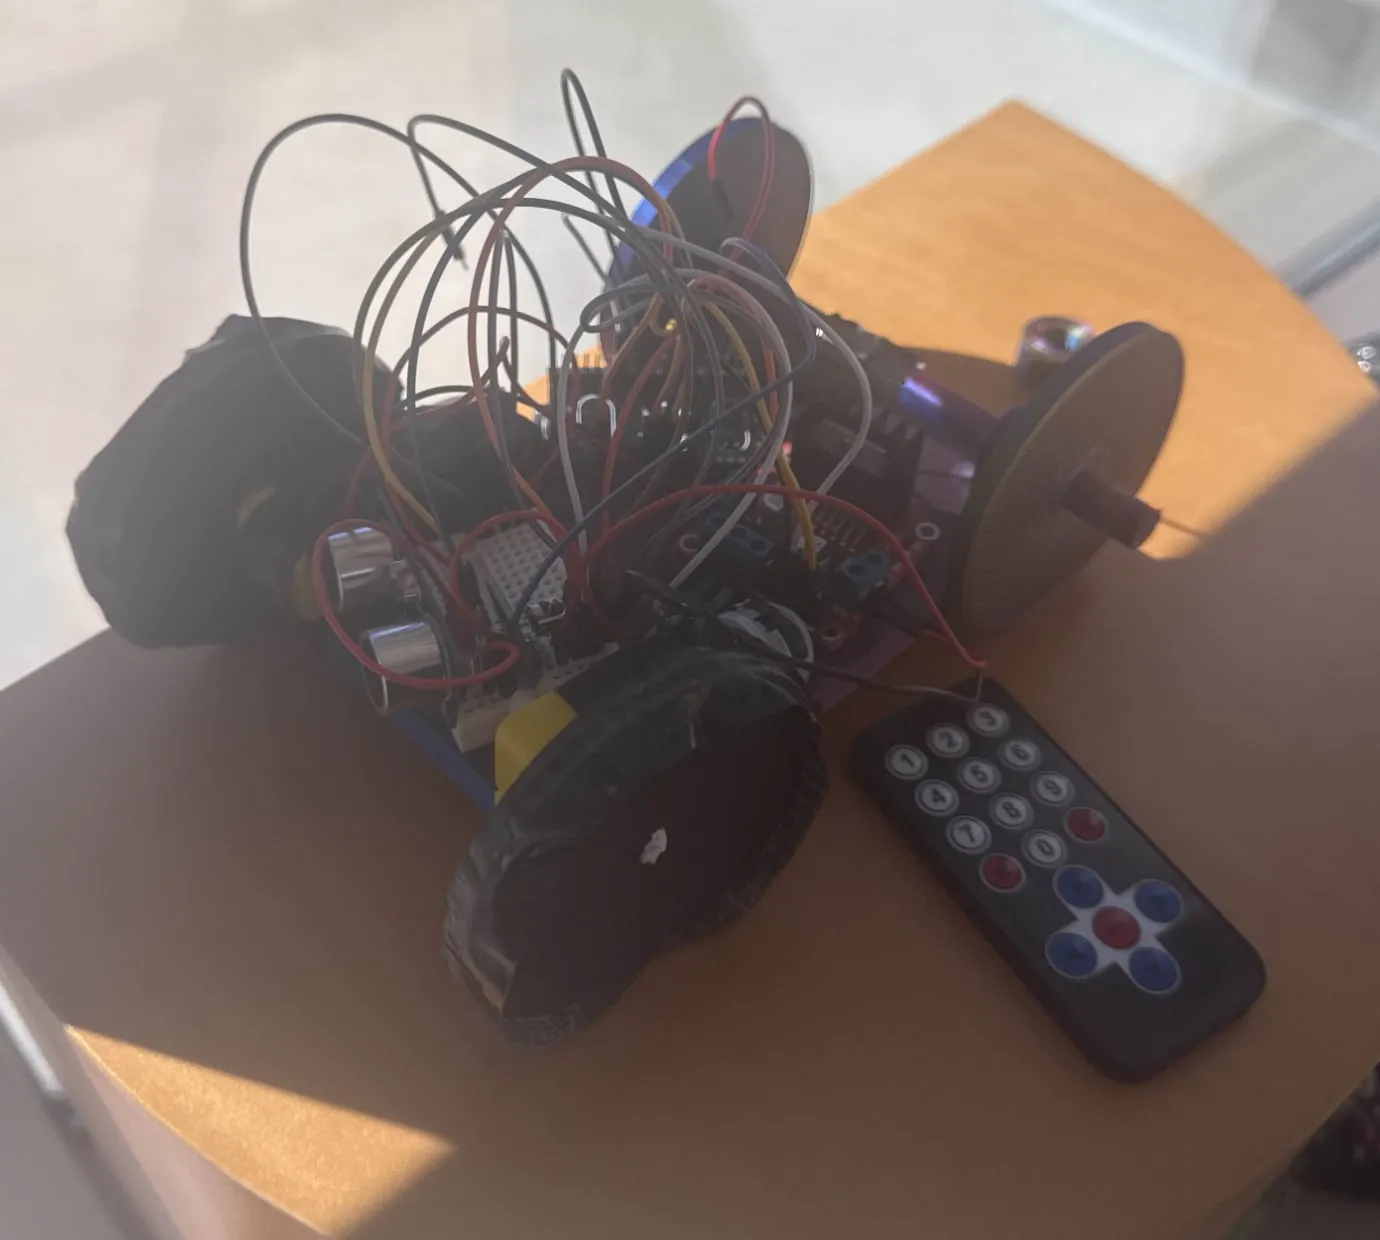
A mobile robot designed, printed, wired, and programmed in three weeks. One of 3 teams out of more than 30 to field a fully working machine.
- When
- Sep 2025 to Nov 2025
- Role
- Mechanical design and firmware
- Sprint
- 3 wk
- Working robots
- 3 of 30+
- Built with
- C++
- ESP32
- SolidWorks
- Bambu Studio
- PWM motor control
- Ultrasonic sensing
A custom mobile robot taken from CAD drawings to working firmware in a three-week sprint. It was one of only 3 teams out of more than 30 to build and deploy a fully functional physical platform.
What I built
- Designed the chassis in SolidWorks and fabricated it on a 3D printer.
- Programmed the ESP32 motor drivers with PWM control.
- Closed the loop with ultrasonic feedback so the robot could handle objects precisely.